Line Follower
2023
A from-scratch line follower robot for OTN 2023: hand-cut MDF chassis, standard gear motors, and a closed loop system. It finished the whole track; the speed race was another story.
In a nutshell
I built a working robot from scratch for a national robotics competition held in Bekasi. It was the first time my school had ever competed in this event, and our robot completed the entire course without a single wrong turn. We lost on speed, but the build, wiring, and programming were all ours from zero.
Why I built this
I built this robot from scratch to represent my school, SMAN 28 Kabupaten Tangerang, at OTN 2023 (UNISMA Bekasi, December 16 to 17, 2023). It was our school's first line follower competition, so we just assumed DIY was the rule. Once we arrived, it turned out every other team was running factory kits. Either way, building it myself taught me the fundamentals: how the sensors, the motor driver, and the code talk to each other.
How it's built
- Custom chassis
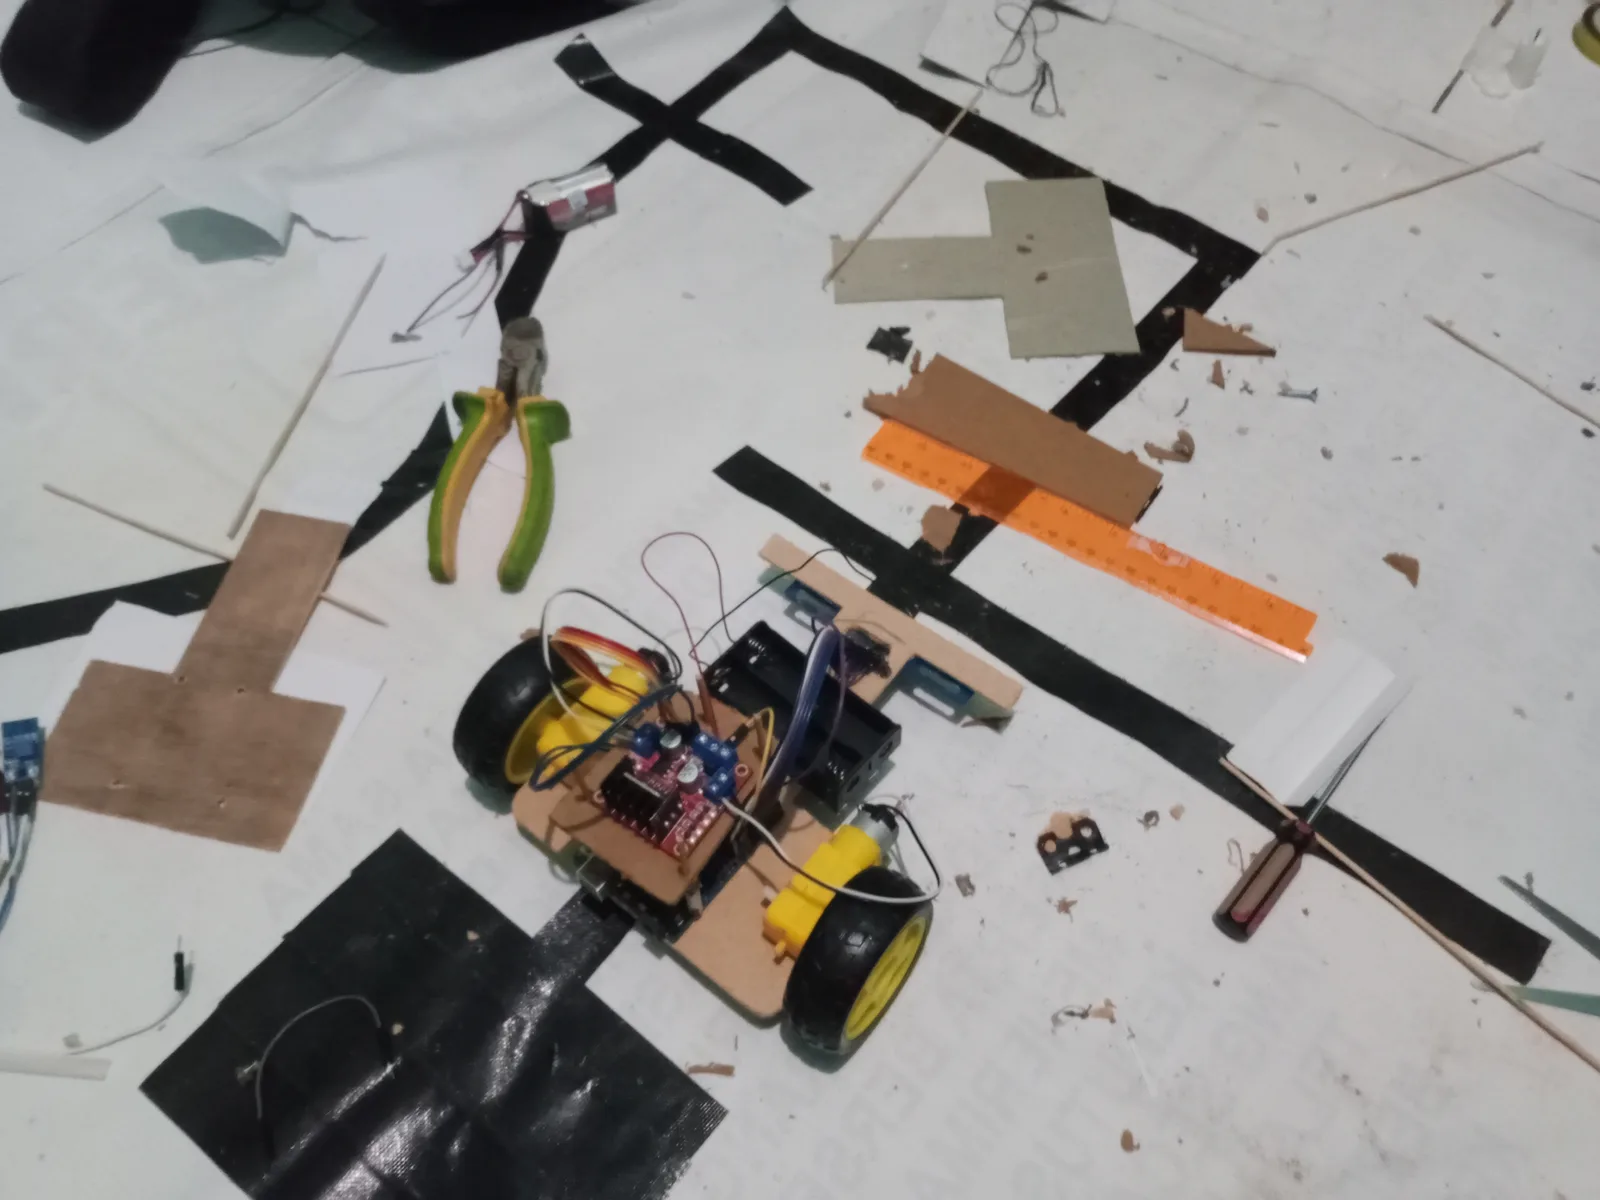
- No precision-cut acrylic chassis here. I cut the base plate by hand from an MDF board and assembled it with supporting parts.
- Drive system
- Standard yellow-gear DC motors on both sides of the wheels. Nothing fancy, but they get the job done.
- Power & control
- An L298N motor driver (the classic red module) sits in the middle of the chassis: battery power goes in on one side, motors get fed on the other, and it relays signals from the microcontroller.
- Line sensors
- An infrared sensor module mounted on a little wooden bracket at the front reads the color contrast of the track.
- Testing
- PID calibration and basic control logic were tested at home on a small handmade track, black tape over a white surface. At school there was a bigger track to play with, and race day was a whole different level of complexity.
Result
On race day the robot ran the entire course from start to finish without ever leaving the line, even though the competition track was more complex than anything I'd tested on before. In terms of lap time, though? It got beaten badly. Standard DC motors, a chunky MDF chassis, and zero racing parts just couldn't keep up with the commercial kits most competitors brought. But the main goal was met: I designed the thing, programmed it, and proved that a closed loop system built from basic components can run stably.
Screenshots
Certificate
View certificate (PDF)